Force Vectors and Moments
“An impressed force is an action exerted upon a body, in order to change its state, either of rest, or of moving uniformly forward in a right line.”
— Isaac Newton, Principia, Definition IV, 1687, translated by Andrew Motte, 1729
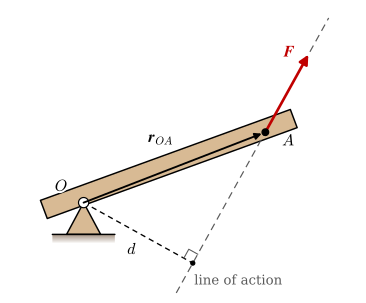
A force is a vector with a place. Its magnitude and direction make an arrow, and its point of application puts that arrow on a line, the line of action, drawn dashed in Figure 2. On a rigid body we may slide a force along its line of action without changing what it does. Moved off the line, the same arrow turns the body differently.
A set of forces does two things to a body. It pushes, and the push is the resultant, the sum of the forces,
\[ \bm R = \sum_i \bm F_i \]
It also turns the body about any point \(O\) we choose. The turning is the moment: for each force, the cross product of the position vector from \(O\) to its line of action with the force, summed over the forces,
\[ \bm M_O = \sum_i \bm r_i\times\bm F_i \]
Every example in this part computes one of these two sums. The work lies in writing \(\bm r\) and \(\bm F\) in components: in the plane, in space, and in a coordinate system turned against the drawing, as in 3.13 Rotation and change of basis.